



Showing all 4 results

Filter by brands

- National Instruments
- PCI ModulesPCI Modules
- PXI Systems
- PXI Chassis
- PXI Controller
- PXI Modules
- PXI Semiconductor Test
- PXI FPGA and RIO Modules
- PXI MXI Interfaces
- PXI Programmable Power Supplies & SMU
- PXI Sensor Measurements
- PXI Signal Generators
- PXI Vision
- PXI Data Acquisition
- PXI Oscilloscopes/Digitizers
- PXI Counter/Timers
- PXI RF and Wireless Test
- PXI GPIB, Ethernet and VXI
- PXI Switches
- PXI Digital Multimeters
- PXI Digital Input/Output
- PXI Industrial Communication
- PXI Dynamic Signal Analysis
- PXI Data Streaming
- CompactDAQ Systems
- CompactRIO Systems
- PCI Modules
- USB Devices
- USRP Software Defined Radio Device
- keysight
- Tektronix
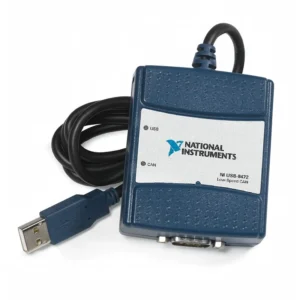
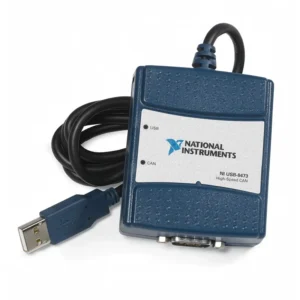
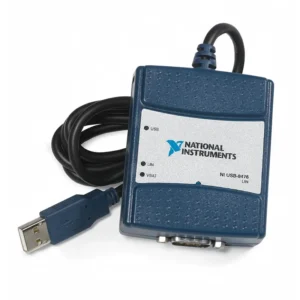
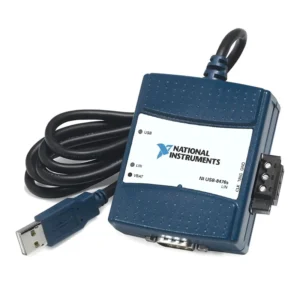
NI USB Industrial Communication Interfaces
NI USB industrial communication interfaces connect a PC to industrial equipment, vehicles, electronic control units, instruments and distributed networks. They are used for monitoring, logging, simulation, diagnostics, automated test and software-based control through protocols such as CAN, CAN FD, LIN, serial and other supported communication standards.
Select an interface by the required protocol and physical layer, not simply by the USB connector. Confirm the connected device, bus topology, data rate, electrical isolation, termination, port count, cable requirements, timestamping and driver compatibility before purchasing hardware.
USB Industrial Communication Interface Types
| Interface Type | Typical Standard | Primary Use | Key Selection Considerations |
|---|---|---|---|
| CAN and CAN FD | Controller Area Network | Vehicle networks, battery systems, industrial machinery and ECU communication | Classic CAN or CAN FD support, bit rate, termination, isolation and channel count |
| LIN | Local Interconnect Network | Automotive body electronics, subnetwork monitoring and simulation | Master or slave role, schedule requirements, signal database and wiring |
| FlexRay | Deterministic automotive network | Vehicle development, validation and network simulation | Topology, channel configuration, timing and software support |
| Serial Communication | RS-232, RS-422 or RS-485 | PLCs, drives, instruments, sensors and legacy industrial equipment | Electrical standard, port quantity, isolation, wiring and duplex mode |
| Industrial Ethernet and Network Interfaces | Ethernet-based communication, where supported | Network-connected instruments, controllers and distributed test equipment | Protocol support, network architecture, addressing and host integration |
| Instrument Communication | Supported instrument-bus and legacy interfaces | Automated test systems and laboratory instrument control | Instrument protocol, driver support, cable type and software API |
How to Select a USB Industrial Communication Interface
1. Identify the Required Protocol
Start with the connected device documentation. Determine whether the device communicates through CAN, CAN FD, LIN, FlexRay, RS-232, RS-422, RS-485, Ethernet or another supported interface.
Protocol names alone are not sufficient. Confirm the physical electrical standard, connector type, cable requirements, network topology and device communication role before selecting hardware.
2. Confirm the Electrical Physical Layer
Communication interfaces that appear similar can use different electrical signaling methods. RS-232, RS-422 and RS-485 are not interchangeable, and CAN, LIN and FlexRay each require their own compatible network interface.
Review logic voltage, common reference, cable length, shield connection, connector pinout and expected electrical environment. Long industrial cables and vehicle installations can introduce noise and ground-potential differences.
3. Determine Port Count and Bus Topology
Count the number of independent buses or serial ports needed. Each separate CAN network, serial device group or isolated subsystem may require its own communication channel.
For RS-485 networks, determine whether the installation uses two-wire or four-wire wiring, half-duplex or full-duplex communication, and multidrop connections. For vehicle networks, identify the network segments that must be logged, simulated or controlled simultaneously.
4. Verify Data Rate and Bus Loading
Confirm the required baud rate, message frequency, frame format and expected traffic load. The selected interface must support not only nominal communication speed but also the full monitoring, transmission, timestamping and logging workload.
CAN FD applications should verify classic CAN compatibility, arbitration-phase requirements and data-phase requirements. High bus traffic can also increase host-computer processing and file-storage demands during long recordings.
5. Evaluate Isolation and Grounding
Electrical isolation can help protect the computer and interface from ground-potential differences, noise and transient conditions. It is particularly important when connecting to industrial machinery, external power systems, long cable runs or vehicle electrical networks.
Isolation does not eliminate the need for correct grounding, shielding and cable routing. Confirm the complete installed wiring arrangement before connecting a USB interface to powered equipment.
6. Plan Termination and Cabling
CAN networks normally require termination at the two physical ends of the bus. Incorrect termination, poor cable selection, long stubs or unsuitable wiring can create intermittent communication faults.
Serial and Ethernet connections also require correct cable type, connector pinout, shielding and network configuration. Confirm whether the required cable, breakout accessory, terminal adapter or termination component is included in the system plan.
CAN, CAN FD, LIN and FlexRay Applications
CAN and CAN FD
CAN is widely used in vehicles, battery systems, industrial equipment and machinery. CAN FD extends classic CAN with larger payload capability and, in supported networks, a faster data phase. Confirm whether the application requires classic CAN only or CAN FD support.
Typical applications include passive bus monitoring, message logging, ECU validation, diagnostic development, hardware-in-the-loop testing and network simulation. Determine whether the interface must only receive data or also transmit and simulate network traffic.
LIN
LIN is commonly used for lower-cost automotive subnets and body-electronics functions. Applications should define the required master or slave behavior, schedule timing, network database and intended role of the connected PC.
FlexRay
FlexRay is a deterministic vehicle-network technology used in selected automotive applications. Confirm network topology, synchronization, channel requirements and software support before selecting an interface.
A USB communication interface provides access to a network. It does not automatically include ECU definitions, message databases, diagnostic files, simulation models or the correct vehicle harness.
Serial and Industrial Equipment Communication
RS-232
RS-232 is commonly used for point-to-point communication with instruments, controllers and legacy devices. Confirm connector pinout, baud rate, handshake signals, cable length and device command protocol.
RS-422 and RS-485
RS-422 and RS-485 use differential signaling and are commonly selected for longer distances or electrically noisy industrial environments. RS-485 can support multidrop networks when the wiring, termination and communication direction are configured correctly.
Host Software Integration
Communication hardware is only one part of the system. Confirm the command set, message format, device protocol documentation and required software API. Legacy equipment may use manufacturer-specific commands that must be implemented by the application.
Software, Timestamping and Data Logging
Supported NI USB communication interfaces use the applicable NI driver and software stack for device recognition, configuration, transmission, reception, logging and analysis. Automotive network interfaces commonly use NI-XNET for supported CAN, LIN and FlexRay applications, while serial devices typically use the relevant NI serial or VISA software environment.
Network logs often need timestamps so communication traffic can be correlated with sensor data, digital events, test commands or fault conditions. Define whether the application needs approximate software timestamps, hardware timestamps or synchronized timing with another measurement system.
For long-duration logging, estimate message traffic, record format, storage capacity and host-computer workload. File writing, display updates and data decoding should not interfere with the communication task when continuous logging is required.
Typical Applications
- Automotive CAN, CAN FD, LIN and FlexRay logging
- ECU development, validation and diagnostic applications
- Battery-management-system monitoring and test
- Industrial PLC, drive and controller communication
- Serial instrument and legacy-equipment integration
- Vehicle-network simulation and hardware-in-the-loop testing
- Production-line communication monitoring
- Automated test-system instrument control
- Field diagnostics and maintenance data collection
- Combined network logging and sensor acquisition
USB Industrial Communication Interface Procurement Guide
Provide the following information for accurate interface selection and quotation:
- Required protocol: CAN, CAN FD, LIN, FlexRay, RS-232, RS-422, RS-485, Ethernet or other
- Connected device manufacturer, complete model and interface documentation
- Required number of independent buses or communication ports
- Required baud rate, message rate and expected bus traffic
- Monitoring, logging, diagnostics, simulation or control requirement
- Need for electrical isolation and expected grounding conditions
- Required connector, cable, breakout, termination and adapter accessories
- Host computer operating system and required NI software environment
- Need for timestamping or synchronization with external measurement hardware
- Required quantity, preferred product condition and delivery destination
FAQ
What is the difference between CAN and CAN FD?
CAN FD extends classic CAN with support for larger payloads and, in supported systems, a faster data phase. The interface, network nodes and application software must all support CAN FD when it is required.
Do I need termination for a CAN interface?
Yes. A CAN network normally requires termination at its two physical ends. Confirm the installed network topology and termination arrangement before connecting the interface.
Can an RS-485 device connect to an RS-232 interface?
No. RS-232 and RS-485 use different electrical signaling methods. Select an interface that matches the connected device’s actual communication standard.
Do I need an isolated USB communication interface?
Isolation is recommended when ground-potential differences, electrical noise, long cables or powered industrial equipment could affect the connection. Review the complete electrical environment before selection.
Can communication data be synchronized with analog measurements?
It can be correlated with measurement data, but achievable timing accuracy depends on the exact interface, drivers, timestamping method and system architecture. Confirm synchronization requirements before purchasing hardware.
Related NI Communication and Test Platforms
Explore NI PCI and USB devices for PC-based communication and measurement hardware. Use CompactDAQ systems for modular communication and sensor acquisition, CompactRIO systems for embedded real-time applications, or NI PXI systems for high-channel-count automated test.
NI USB Industrial Communication Interfaces from PXISOURCE
PXISOURCE supports engineers and procurement teams with USB industrial communication interface selection, protocol and accessory matching, driver compatibility review and sourcing for new applications, spare inventory and legacy-system replacement.
Need help selecting the right NI USB industrial communication interface? Email sales@pxisource.com or contact PXISOURCE on WhatsApp.