



Showing all 6 results

Filter by brands

- National Instruments
- PCI ModulesPCI Modules
- PXI Systems
- PXI Chassis
- PXI Controller
- PXI Modules
- PXI Semiconductor Test
- PXI FPGA and RIO Modules
- PXI MXI Interfaces
- PXI Programmable Power Supplies & SMU
- PXI Sensor Measurements
- PXI Signal Generators
- PXI Vision
- PXI Data Acquisition
- PXI Oscilloscopes/Digitizers
- PXI Counter/Timers
- PXI RF and Wireless Test
- PXI GPIB, Ethernet and VXI
- PXI Switches
- PXI Digital Multimeters
- PXI Digital Input/Output
- PXI Industrial Communication
- PXI Dynamic Signal Analysis
- PXI Data Streaming
- CompactDAQ Systems
- CompactRIO Systems
- PCI Modules
- USB Devices
- USRP Software Defined Radio Device
- keysight
- Tektronix
NI C Series Motion Control Modules
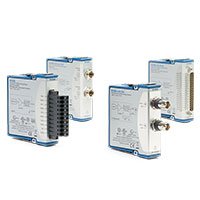
NI C Series motion control modules connect CompactRIO systems to motor drives, encoders, limit switches and machine-control signals. They are used in automated test, robotics, positioning, assembly, material handling and embedded-control applications that require deterministic motion commands and feedback integration.
A complete motion system includes the CompactRIO controller, motion control module, drive, motor, feedback device, mechanical load, power supply, limits and safety circuit. Select the module according to axis count, drive-command type, feedback interface, timing requirements, isolation and software architecture.
Motion Control System Architecture
| System Component | Primary Function | What to Verify |
|---|---|---|
| CompactRIO Controller | Runs real-time application logic and coordinates the complete motion system | Controller performance, real-time support, FPGA resources and software compatibility |
| C Series Motion Control Module | Interfaces motion commands, feedback and machine I/O with the CompactRIO platform | Drive interface, axis count, signal levels, timing and chassis compatibility |
| Motor Drive | Supplies controlled power to the motor based on command signals | Supported command type, supply voltage, current rating, tuning and fault signals |
| Motor or Actuator | Produces linear or rotary movement | Torque, speed, load, travel, mechanical coupling and duty cycle |
| Feedback Device | Reports position, direction, speed or actual motion state | Encoder type, resolution, output level, cable length and reference requirements |
| Safety and Limit Circuit | Provides independent motion limits and fault protection | Limit switches, emergency stop, safe torque off and machine safety design |
Motion Control Interface Types
Stepper Motor Control
Stepper motor systems commonly use pulse and direction commands to control incremental motion. They can be suitable for positioning applications where the mechanical load, acceleration, speed range and position accuracy are understood.
Confirm whether closed-loop position feedback is required. An open-loop stepper system may not detect a missed step caused by overload, mechanical binding or incorrect acceleration settings.
Servo Drive Interface
Servo systems use a drive and feedback device to control position, velocity or torque. The motion module must be compatible with the command method accepted by the drive, such as pulse/direction, analog command, digital interface or another specified control architecture.
Review drive fault outputs, enable signals, brake control, feedback routing and tuning requirements. The selected interface must support the complete drive-control sequence, not only the nominal motion command.
Encoder and Position Feedback
Incremental encoders commonly provide A and B phases, with an optional index pulse. Other feedback devices can use different electrical or protocol interfaces. Confirm signal type, resolution, maximum edge rate, cable arrangement and any differential-input requirement.
Position feedback is essential when the application must verify actual movement, compensate for missed motion or maintain accurate closed-loop control.
Motion-Related Digital I/O
Motion systems often require additional digital signals for drive enable, home position, positive and negative limits, machine status, fault indication, part detection and interlocks. Plan these signals alongside the motion interface rather than treating them as afterthoughts.
How to Select a C Series Motion Control Module
1. Define the Number and Type of Axes
List every axis that must be controlled, including linear stages, rotary axes, conveyors, feeders, actuators and auxiliary mechanisms. Determine whether each axis uses a stepper motor, servo motor, pneumatic actuator or another motion technology.
Axis count alone is not enough. Confirm whether all axes must move simultaneously, whether they require coordinated motion and whether each axis needs independent feedback, limits and fault handling.
2. Identify the Drive Command Interface
Review the motor-drive documentation to determine its accepted command type and electrical levels. A motion control module must match the drive interface, connector wiring, common reference and required enable or fault signals.
Do not assume that a drive with a similar connector uses the same control method. Verify command voltage, pulse polarity, direction logic, analog range, update behavior and required external power.
3. Confirm Feedback Requirements
Determine whether the system requires open-loop positioning, encoder-based verification or full closed-loop control. Define the required position resolution, speed measurement, homing behavior and acceptable positioning error.
For encoder-based systems, calculate the highest expected pulse rate from the encoder resolution and maximum motor speed. The selected interface must sustain this rate with suitable margin.
4. Define Motion Profile Requirements
Specify maximum speed, acceleration, deceleration, travel range, load inertia, duty cycle and required move profiles. Sudden changes in acceleration can cause mechanical stress, missed steps, following errors or drive faults.
Applications requiring coordinated axes, cam profiles, electronic gearing or synchronized motion should be designed at the full system level, including controller performance and software architecture.
5. Evaluate Determinism and Control Latency
Motion control requires predictable timing. CompactRIO FPGA and real-time architectures can support deterministic handling of feedback, command generation, limits and fault conditions when designed for the required loop rate.
Calculate the complete control path, including feedback acquisition, FPGA logic, controller processing, output update, drive response and mechanical motion. A fast controller does not compensate for slow or unsuitable drive and feedback interfaces.
6. Review Safety and Machine Protection
Motion safety must be designed independently from ordinary software control. Review emergency-stop circuits, travel limits, drive fault outputs, safe torque off, mechanical stops, guarding and applicable machine-safety requirements.
Do not rely only on an application command to protect personnel or equipment. Safety functions should be designed, validated and maintained according to the requirements of the installed machine.
CompactRIO FPGA and Real-Time Motion Control
CompactRIO systems are well suited to embedded motion applications that require deterministic timing, feedback processing and integration with additional C Series I/O. FPGA logic can be used for custom pulse generation, encoder decoding, limit handling, triggering and high-speed machine-state processing.
The real-time controller can coordinate motion sequences, state machines, supervisory logic, user interfaces, network communication and data logging. This separation helps keep time-critical control functions independent from slower software tasks.
Confirm the exact motion module’s compatibility with the selected CompactRIO chassis, controller, software version and intended LabVIEW FPGA or real-time application architecture.
Signal Integrity, Grounding and Cabling
Drive and Encoder Cables
Use suitable cables for encoder feedback, low-level command signals and high-power motor wiring. Keep sensitive feedback and command cables separated from motor power cables, switching supplies and contactors where practical.
Confirm shield termination, ground reference, connector pinout, strain relief and cable length. Electrical noise can cause false encoder counts, unstable drive commands or intermittent faults.
Isolation and Common-Mode Conditions
Evaluate isolation requirements when the controller, drive and machine equipment use different power sources or are installed across long cable runs. Ground-potential differences and common-mode noise can affect motion reliability and connected measurement hardware.
Commissioning and Validation
Commission each axis with conservative motion limits before operating at full speed or load. Validate direction, scaling, home sequence, limit behavior, fault response, feedback count direction and emergency-stop behavior as part of the system acceptance process.
C Series motion control modules usually interface to an external motor drive; they are not a substitute for the drive, motor power supply or machine-safety circuit. Confirm the complete motion architecture before ordering.
Typical Applications
- Robotic positioning and machine automation
- Servo and stepper motor test systems
- Material handling, packaging and conveyor control
- Linear stages, rotary tables and precision positioning
- Automated assembly and inspection equipment
- Dynamometer and motor-performance test stands
- Laboratory motion-control and research platforms
- Hardware-in-the-loop and mechatronic validation
- Industrial machinery retrofits and embedded control
- Automotive, aerospace and energy-system automation
C Series Motion Control Module Procurement Guide
Provide the following information for accurate motion-module selection:
- Number of axes and required simultaneous or coordinated motion behavior
- Motor type, manufacturer, model and required operating range
- Drive manufacturer, complete model and command-interface documentation
- Required control method: pulse/direction, analog command, digital interface or other
- Required maximum speed, acceleration, travel range and load characteristics
- Encoder or feedback-device type, resolution, output level and cable length
- Required home, limit, enable, brake, fault and interlock signals
- Required control-loop rate, trigger behavior and synchronization requirements
- Existing CompactRIO chassis and controller model
- LabVIEW, NI driver, real-time and FPGA software requirements
- Required cables, terminal blocks, breakout accessories and external power arrangements
- Required quantity, preferred product condition and delivery destination
FAQ
Can a C Series motion control module power a motor directly?
Motion control modules typically interface with an external motor drive. The drive supplies the power required by the motor, while the CompactRIO system provides command, feedback and supervisory control functions.
What is the difference between stepper and servo control?
Stepper systems often use incremental pulse commands and can operate open loop. Servo systems generally use drive feedback to regulate position, velocity or torque. The correct choice depends on the required speed, load, accuracy and fault-detection behavior.
Do I need an encoder for motion control?
Not every stepper application uses encoder feedback, but encoders are important when actual position, speed verification, closed-loop control or missed-motion detection is required.
Can I control multiple axes from one CompactRIO system?
Yes, subject to the selected modules, available I/O, controller performance, FPGA design and required coordinated-motion behavior. Confirm all axis, feedback and safety requirements before selecting the architecture.
Why are limit switches important?
Limit switches help prevent movement beyond the allowed travel range. They should be incorporated into a properly designed machine-protection and safety system, not treated only as normal application inputs.
Related NI Modular I/O Solutions
Use CompactRIO systems for embedded FPGA and real-time motion control. Combine motion interfaces with the broader NI C Series module range for encoder feedback, digital limits, analog monitoring, sensor measurement and communication I/O. For PC-based test and automation architectures, explore NI PXI systems.
NI C Series Motion Control Modules from PXISOURCE
PXISOURCE supports engineers and procurement teams with C Series motion-module selection, CompactRIO compatibility review, drive and encoder interface matching, and sourcing for new automation systems, spare inventory and legacy-control replacement projects.
Need help selecting the right NI C Series motion control module? Email sales@pxisource.com or contact PXISOURCE on WhatsApp.